Self-Balancing Bike Workshop Series
Details

How does a machine notice that it is fallingโ€”and correct itself?

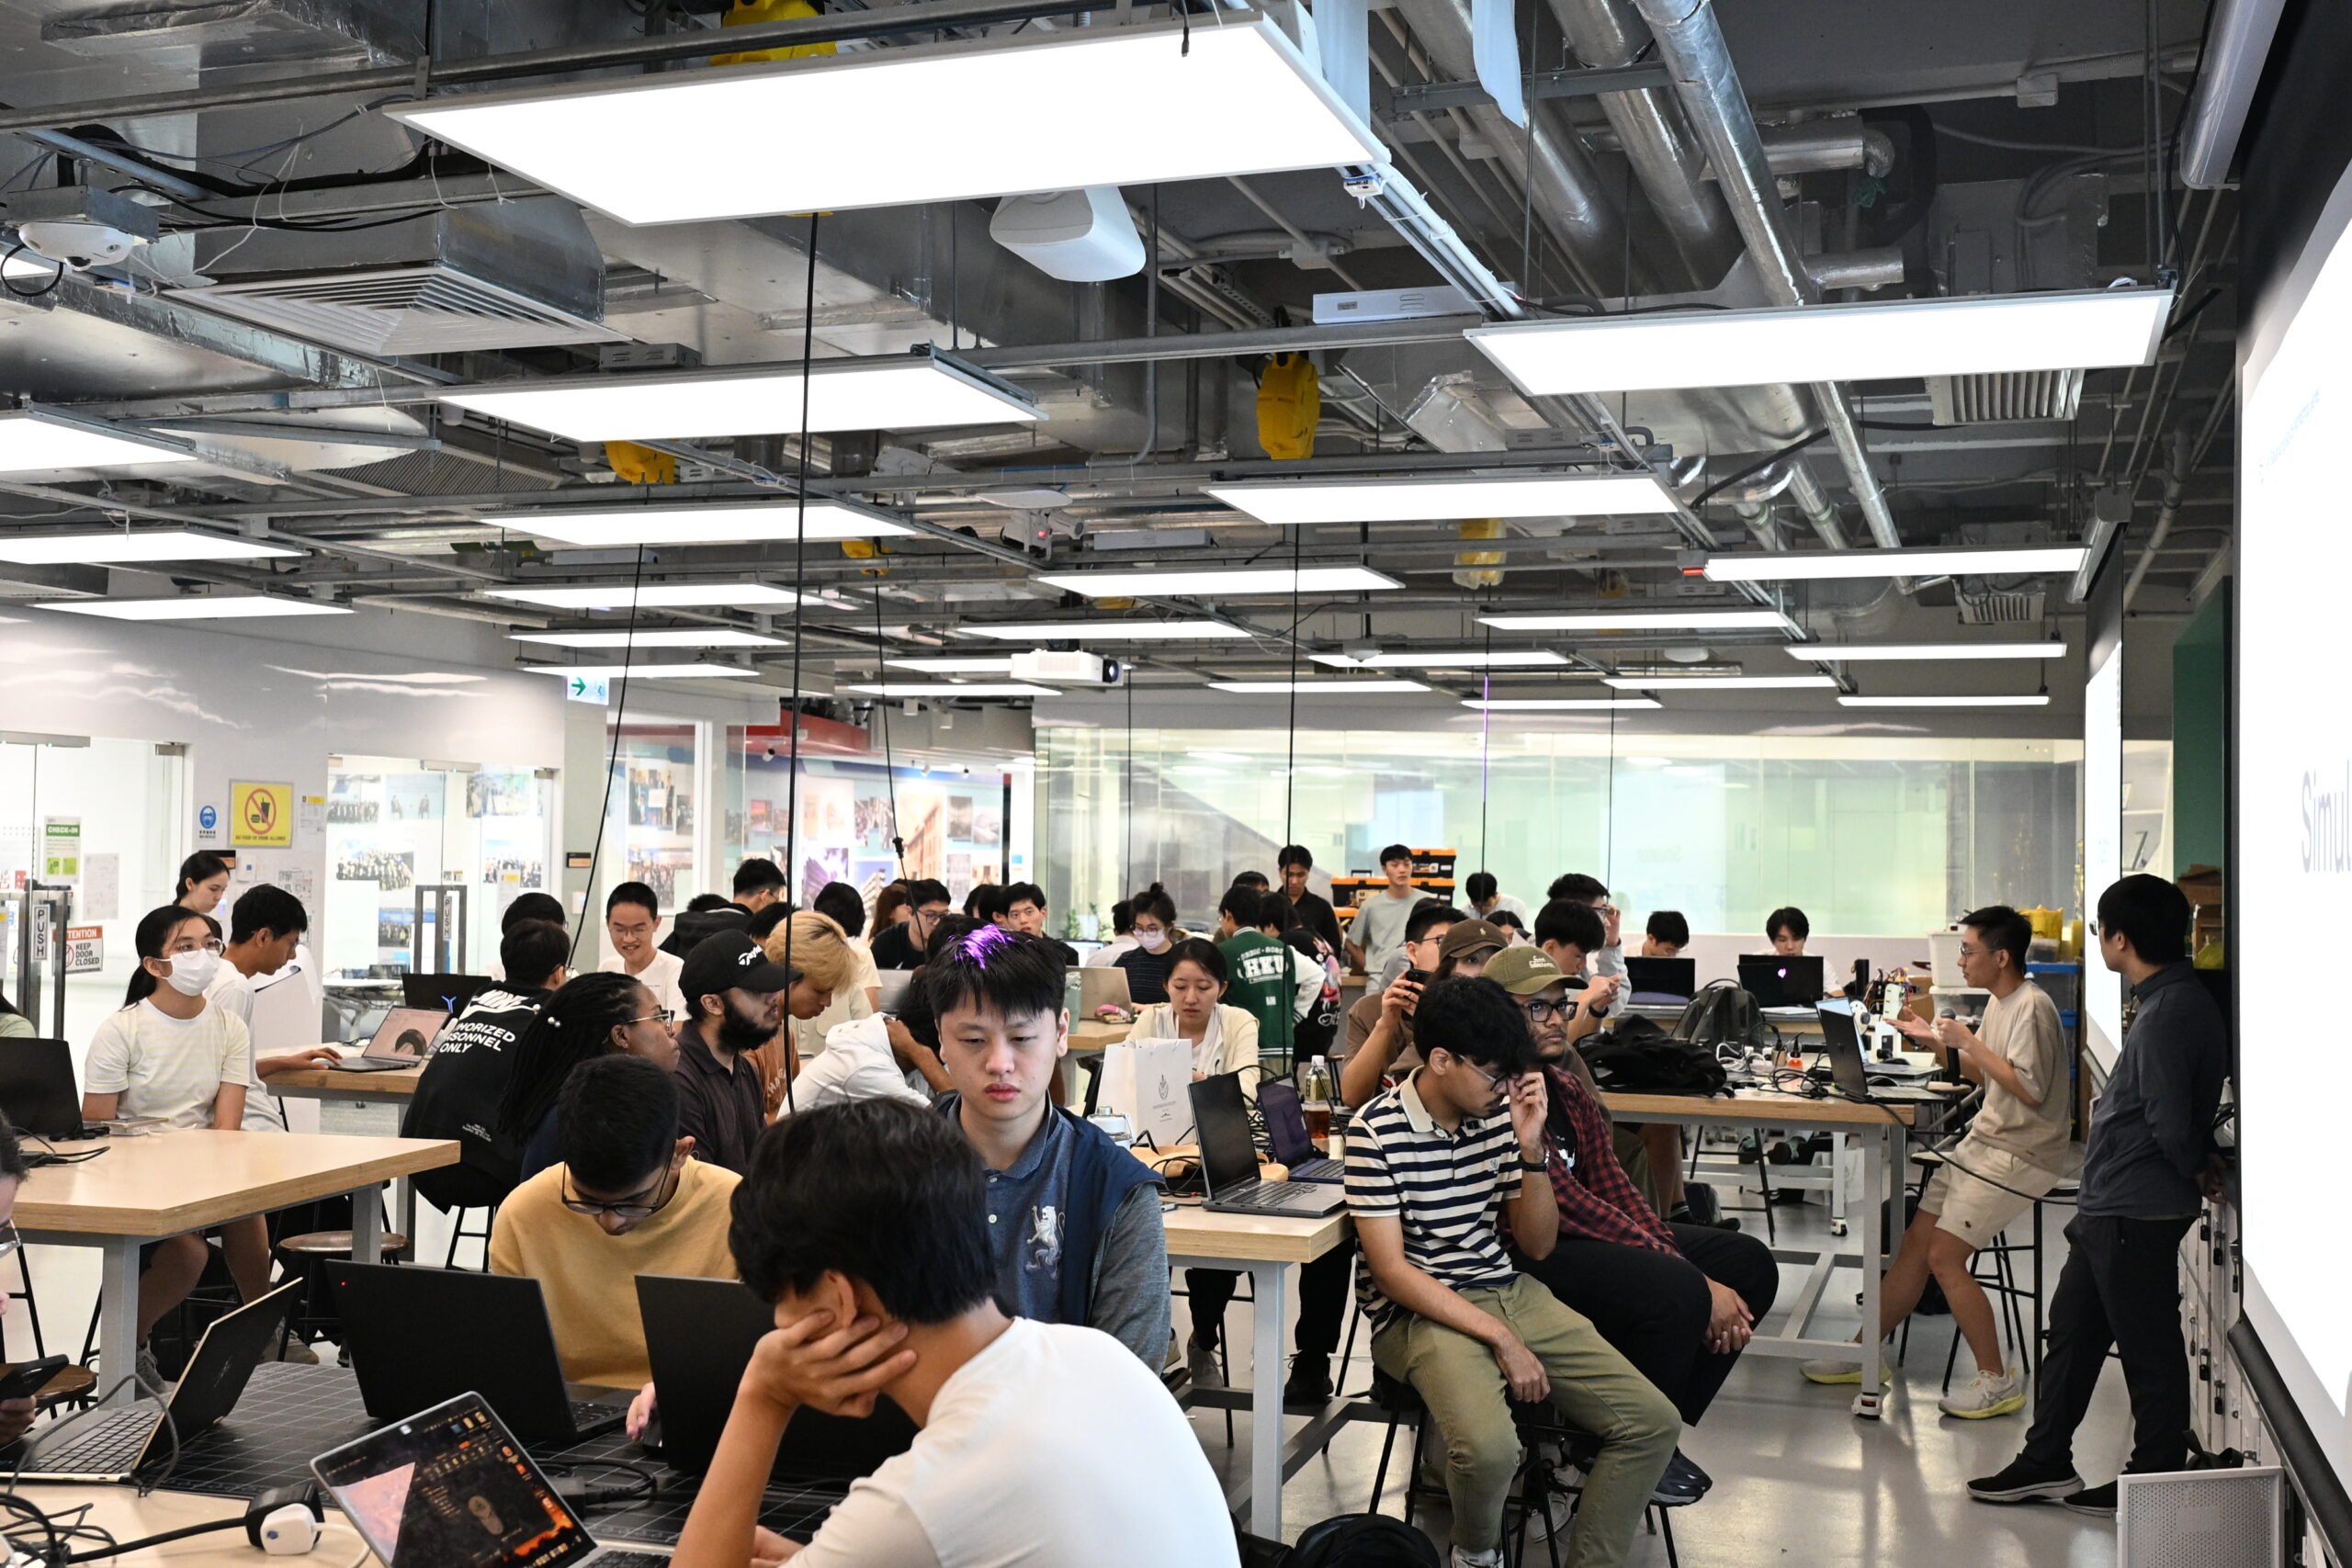
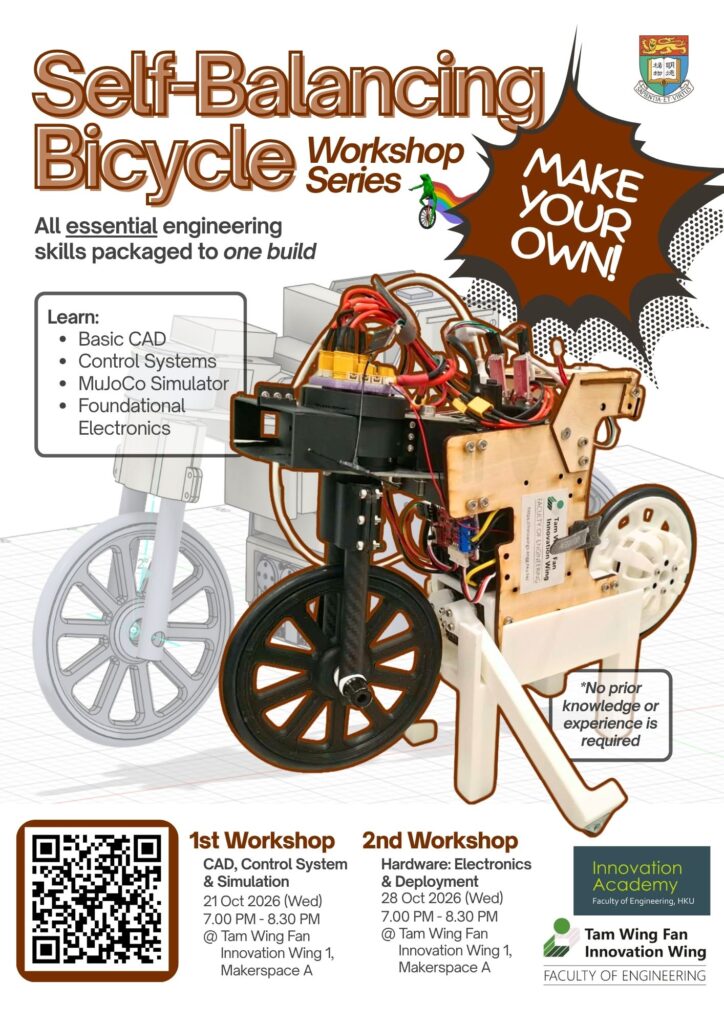
We are excited to invite you to a two-part workshop series where you will build the control system behind a self-balancing bicycle. Rather than trying to build a full-sized bicycle in two evenings, this series is designed to help you understand and build a robot’s most critical system: sense, calculate, correct, and balance.

In this hands-on program, you will follow the complete engineering workflow from virtual simulation to working hardware.

Workshop 1 ยท Simulate the Balance

๐Ÿ“… 21 October 2026 (Wed) | ๐Ÿ•– 7:00 PM โ€“ 8:30 PM

Learn why bicycles fall, how feedback control works, and how PID keeps a system upright. You will tune a virtual bicycle in the MuJoCo Simulator and adjust its response until it balances successfully.

  • You will make: A self-balancing bicycle simulation with your own PID settings.

Workshop 2 ยท Build the Controller

๐Ÿ“… 28 October 2026 (Wed) | ๐Ÿ•– 7:00 PM โ€“ 8:30 PM

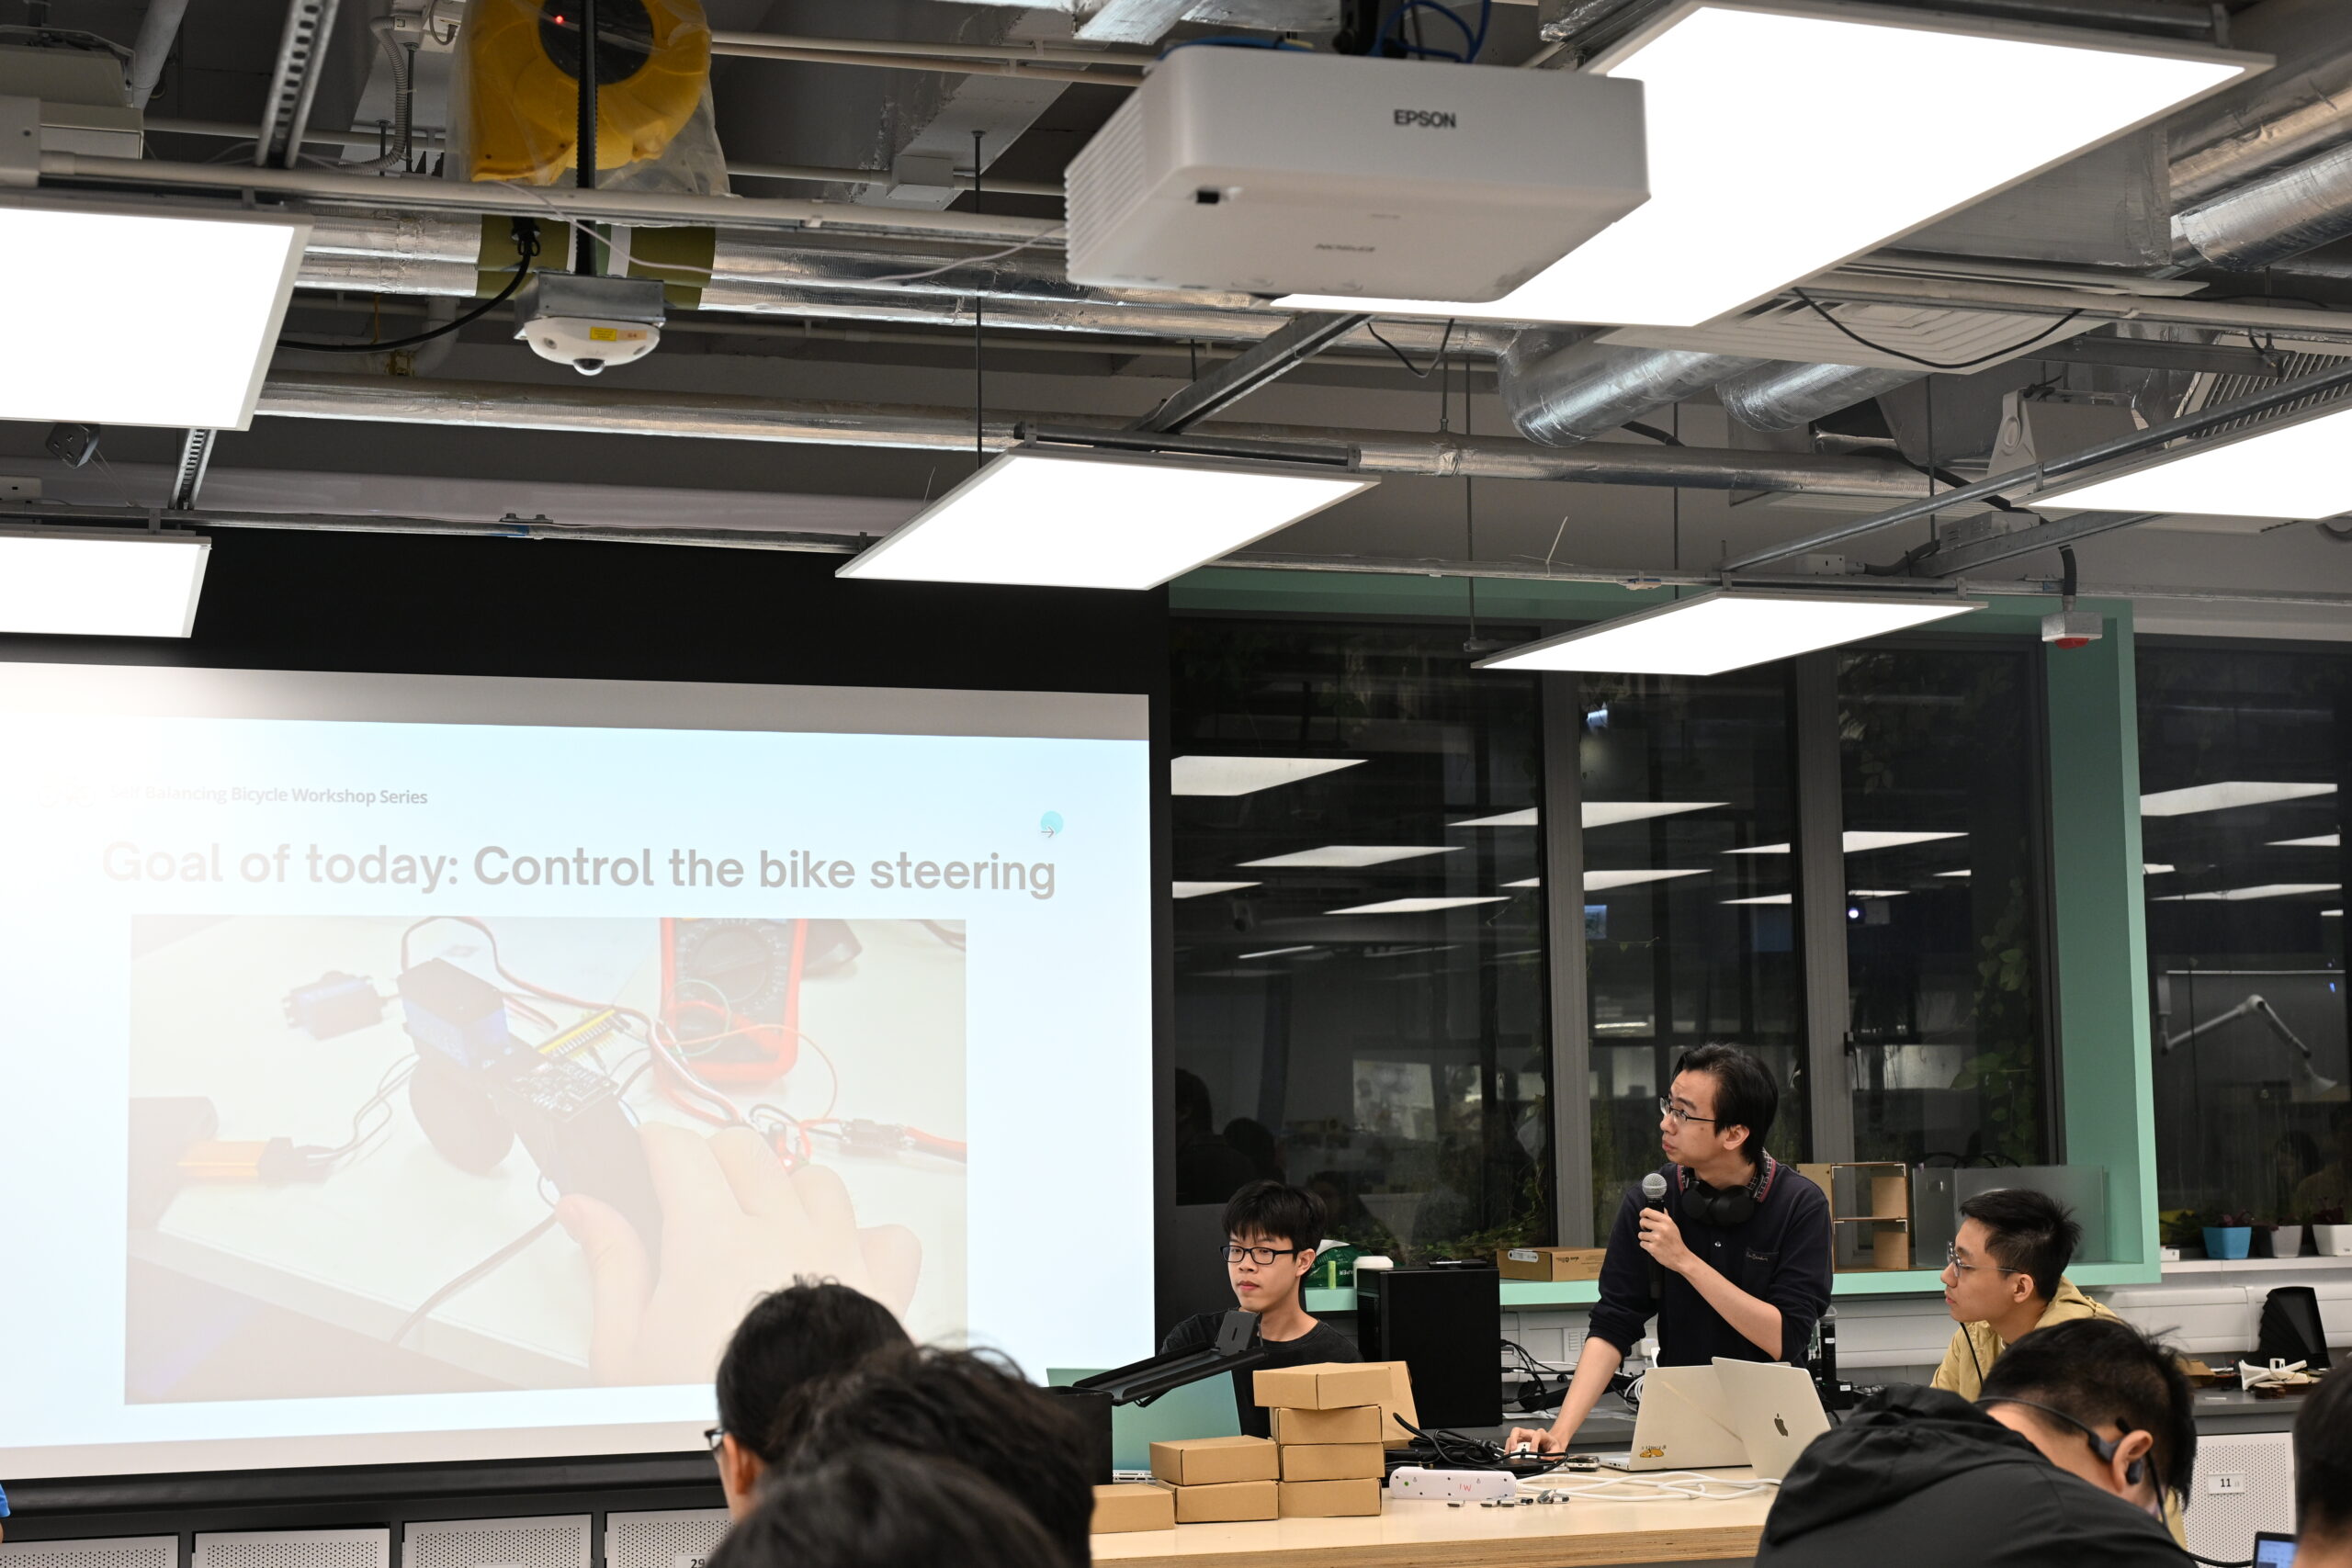
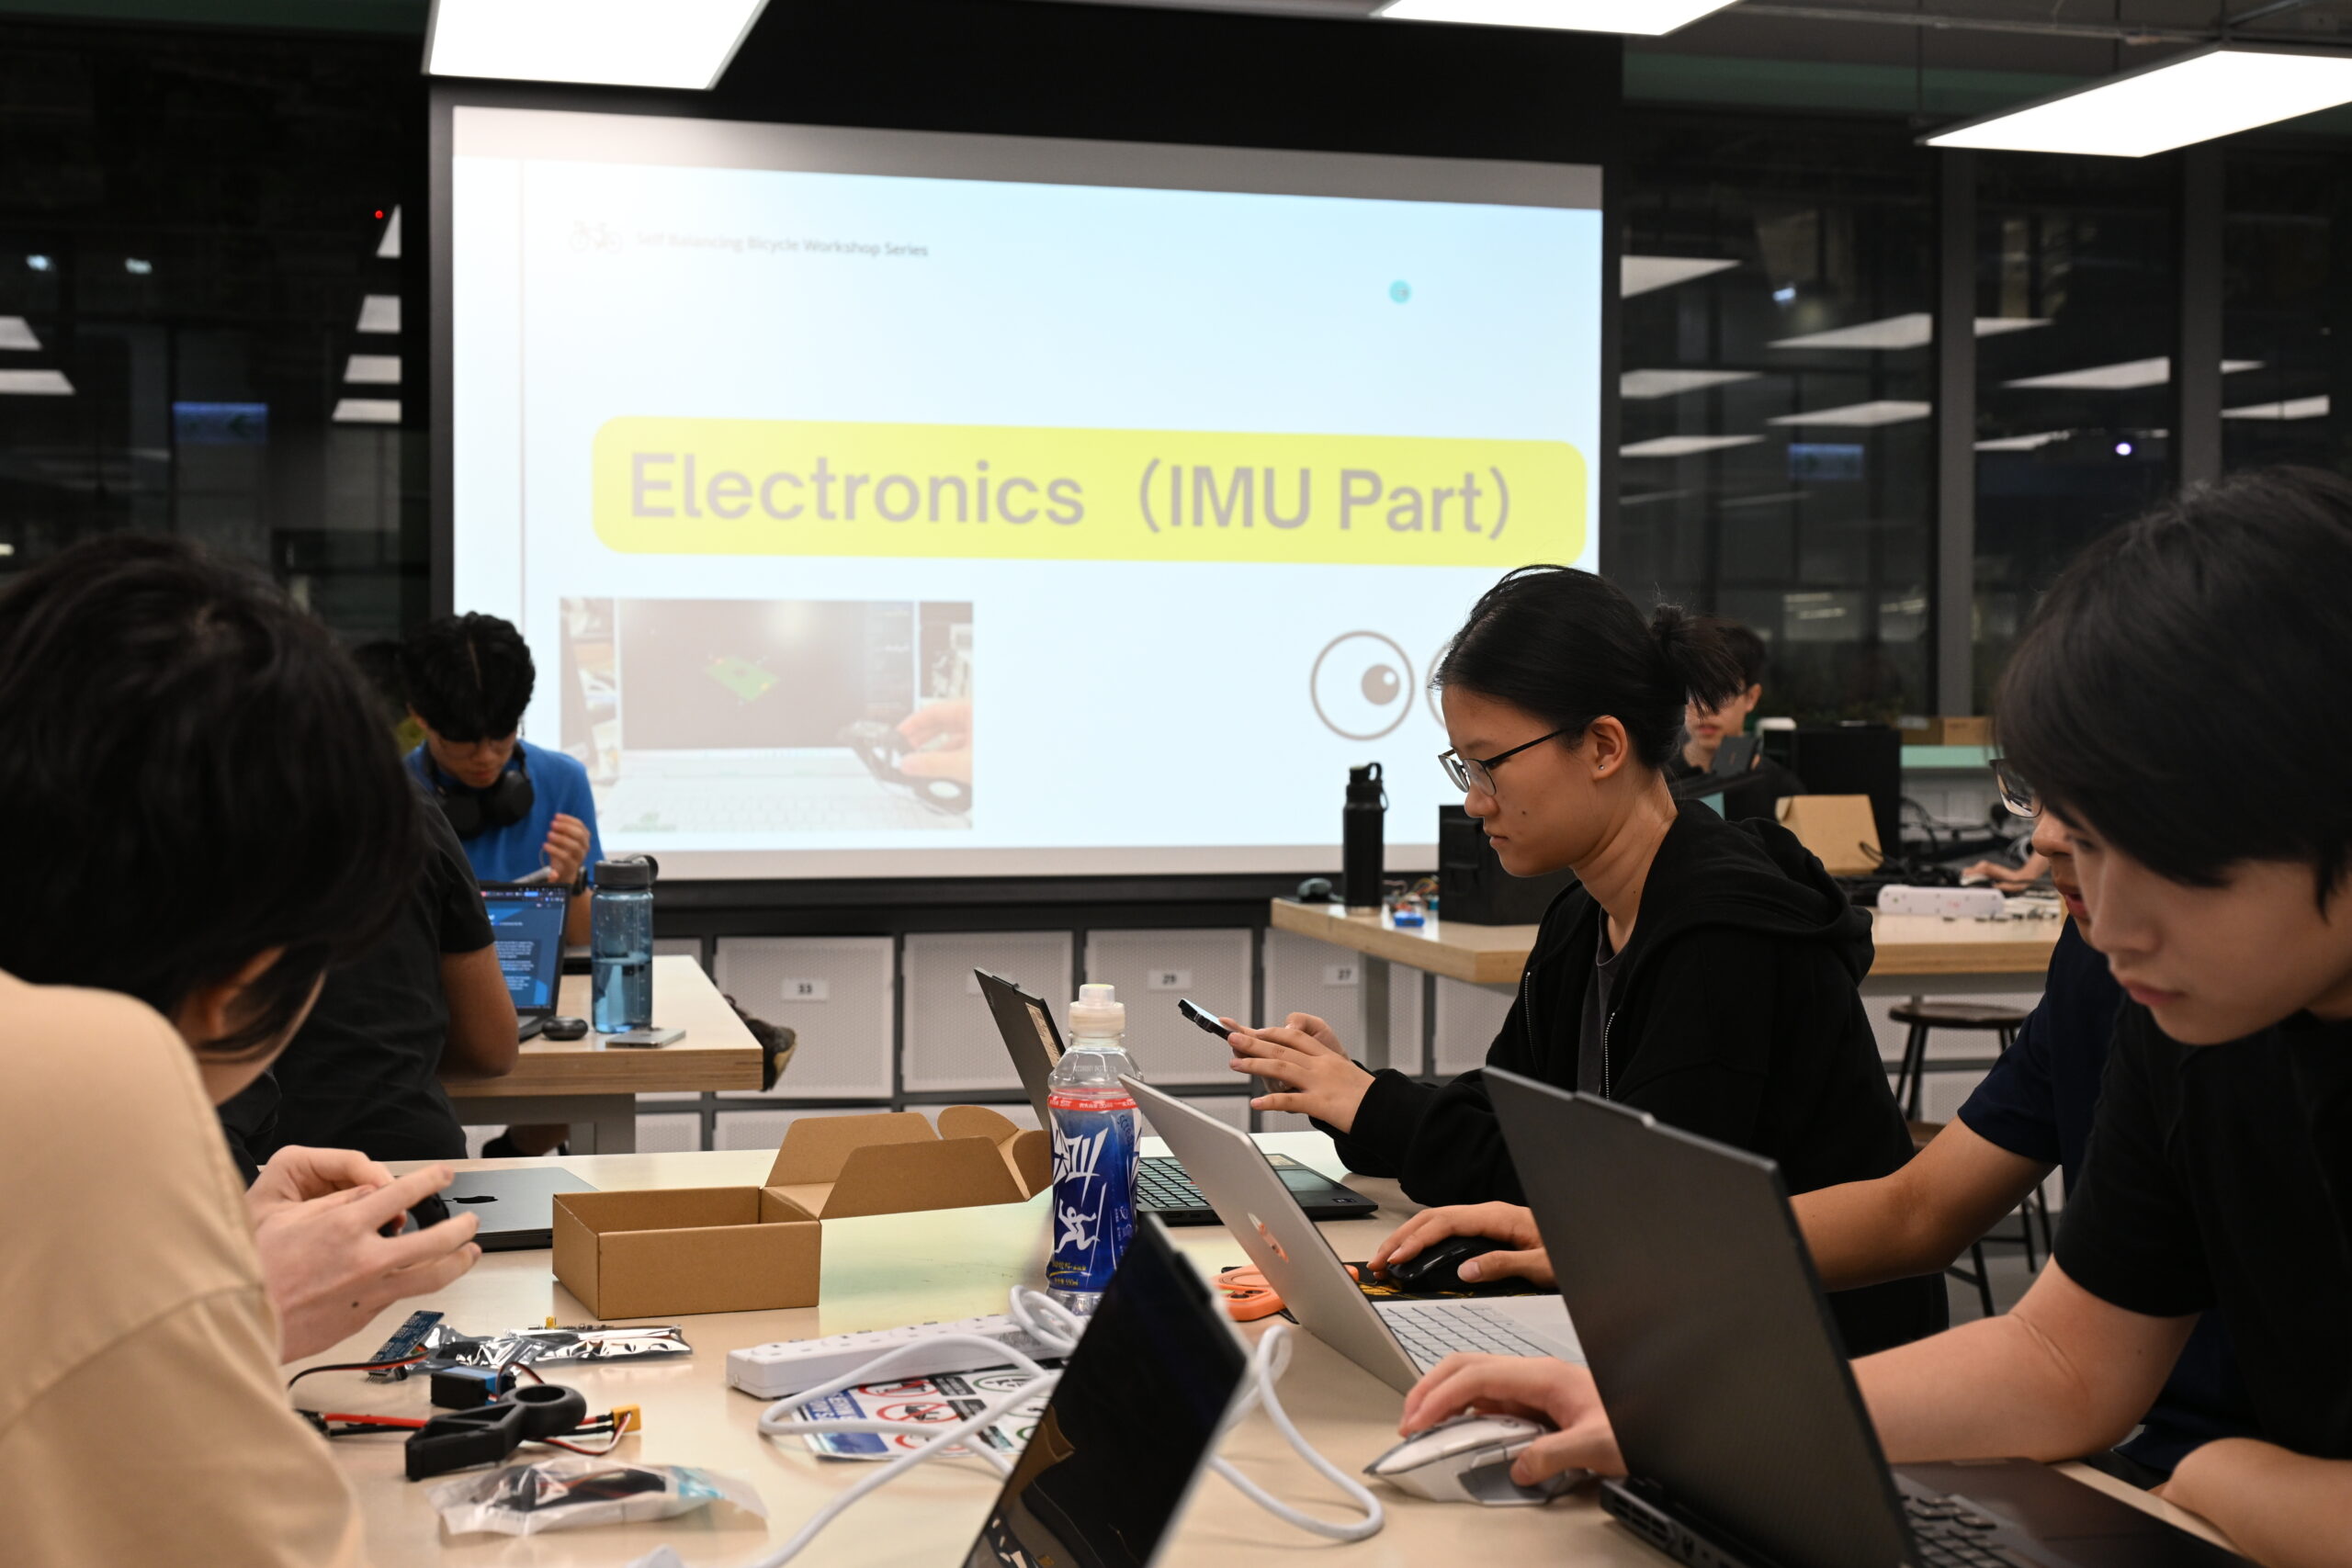
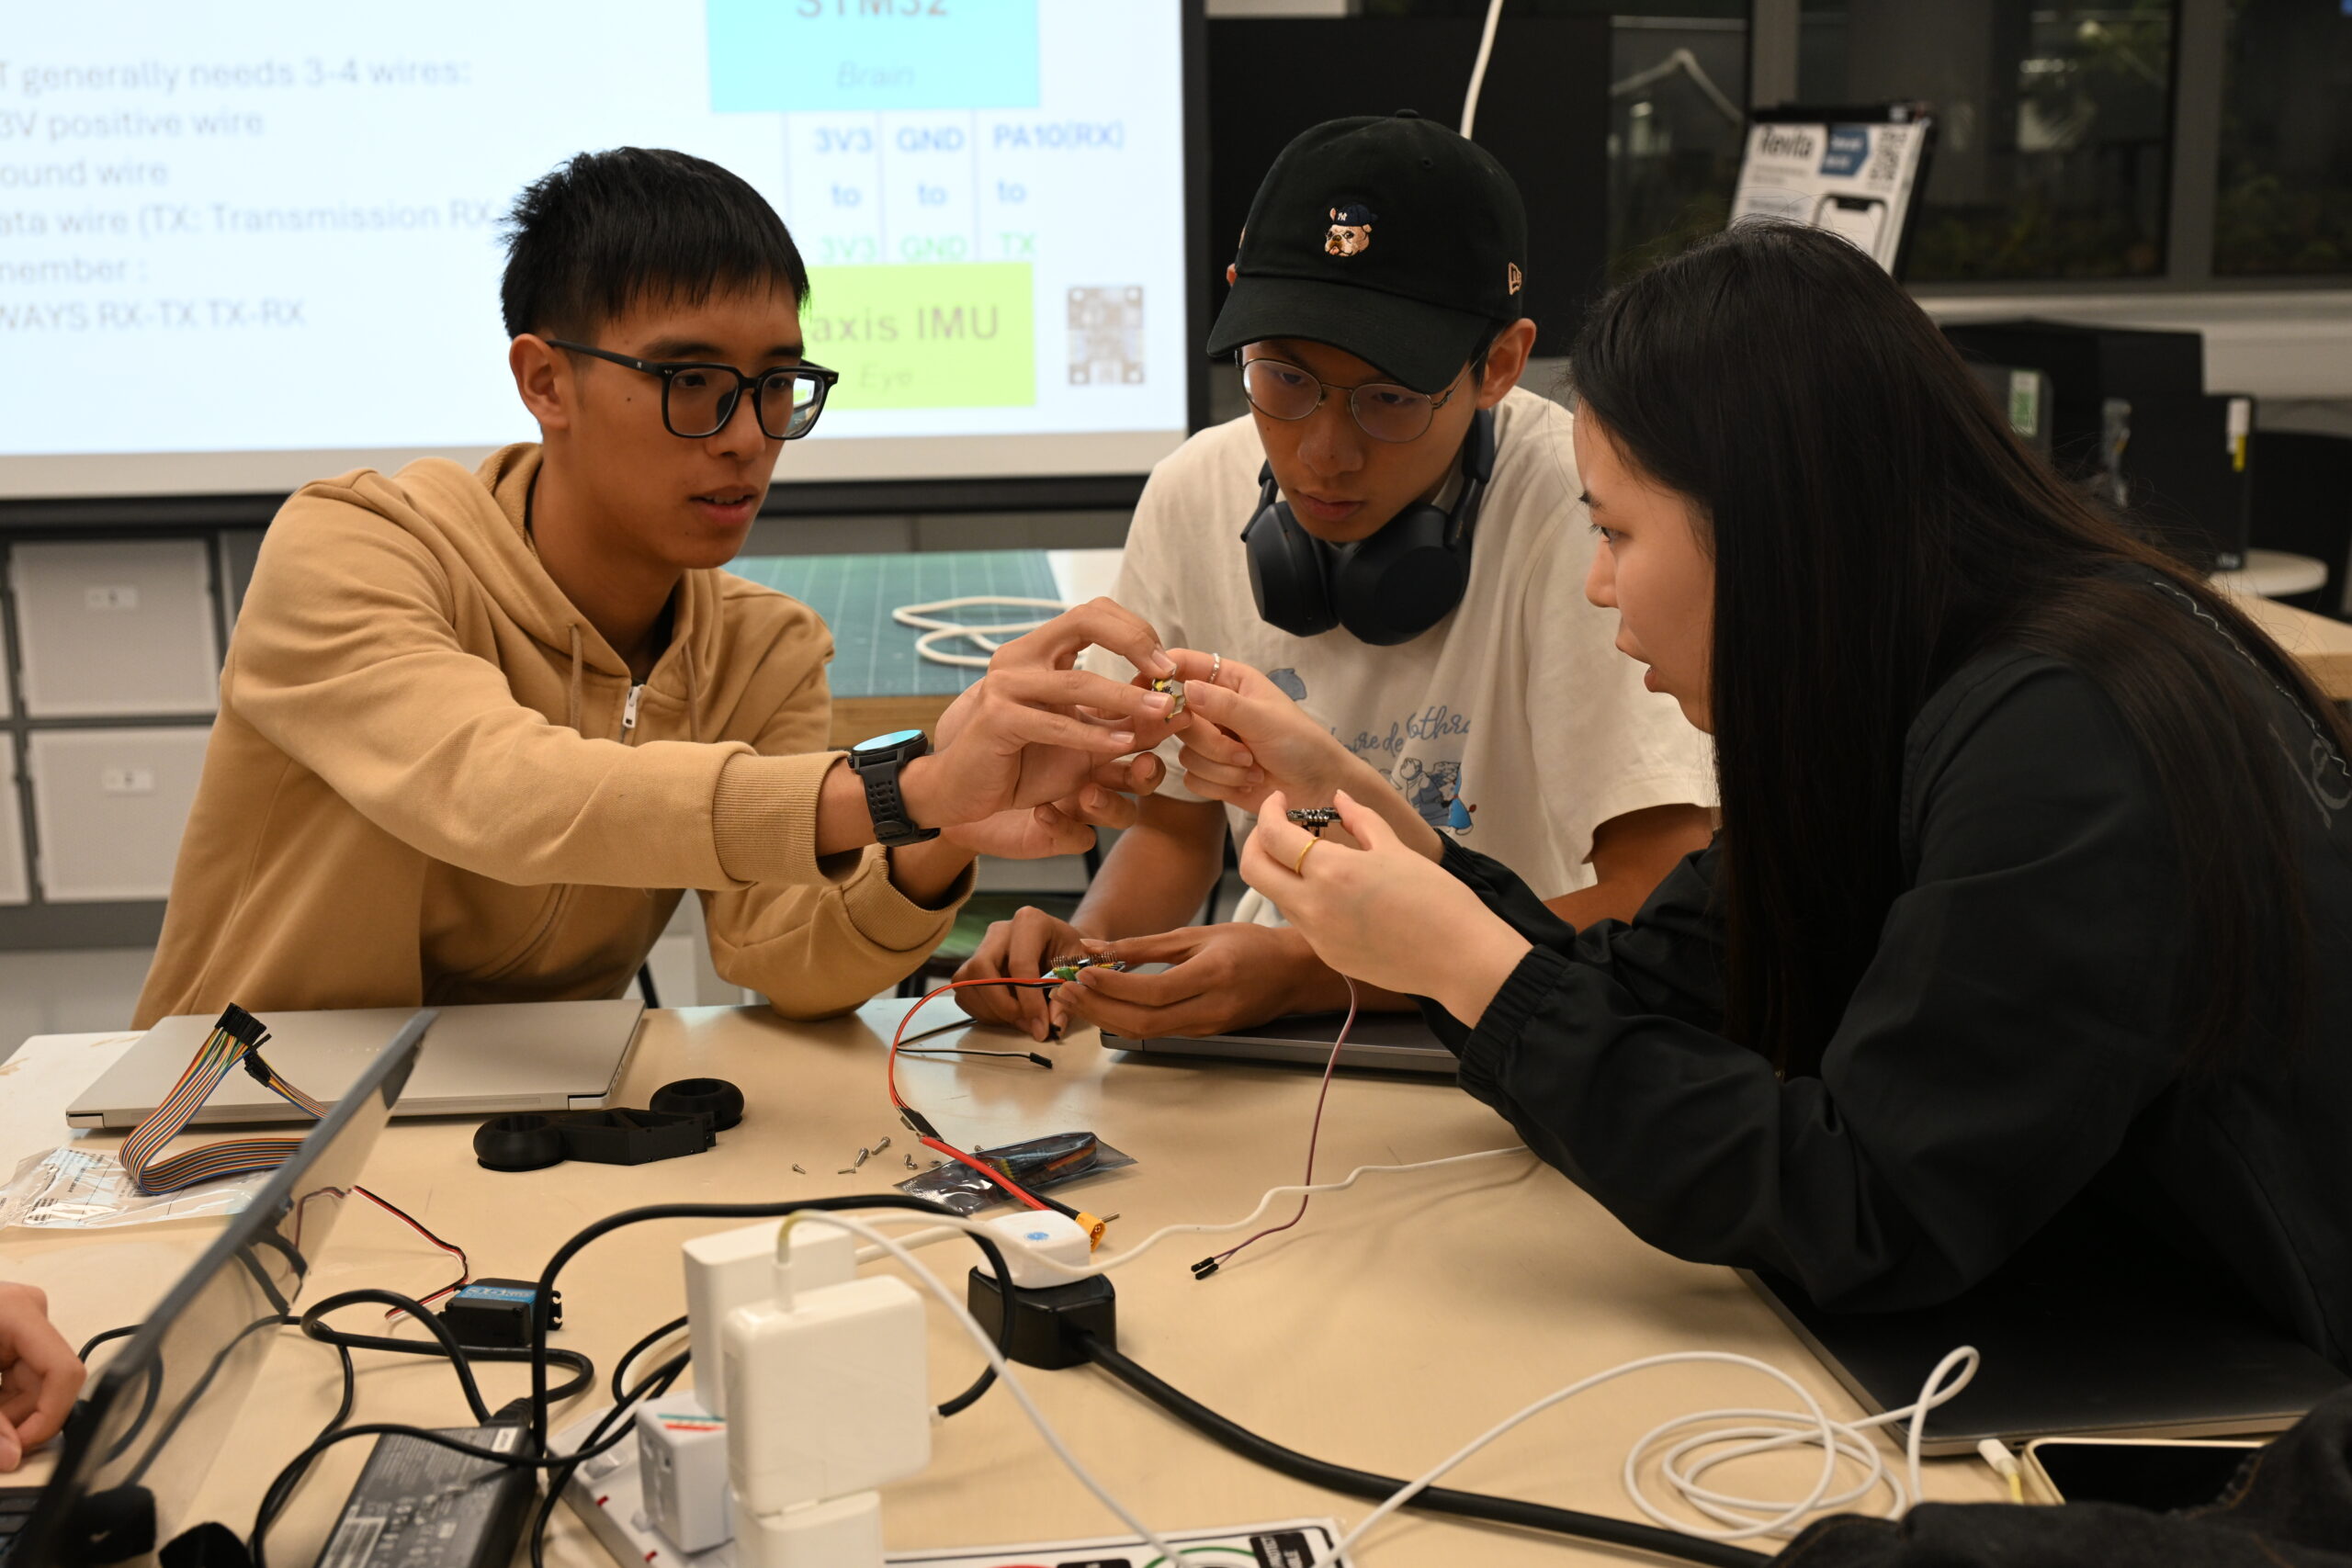
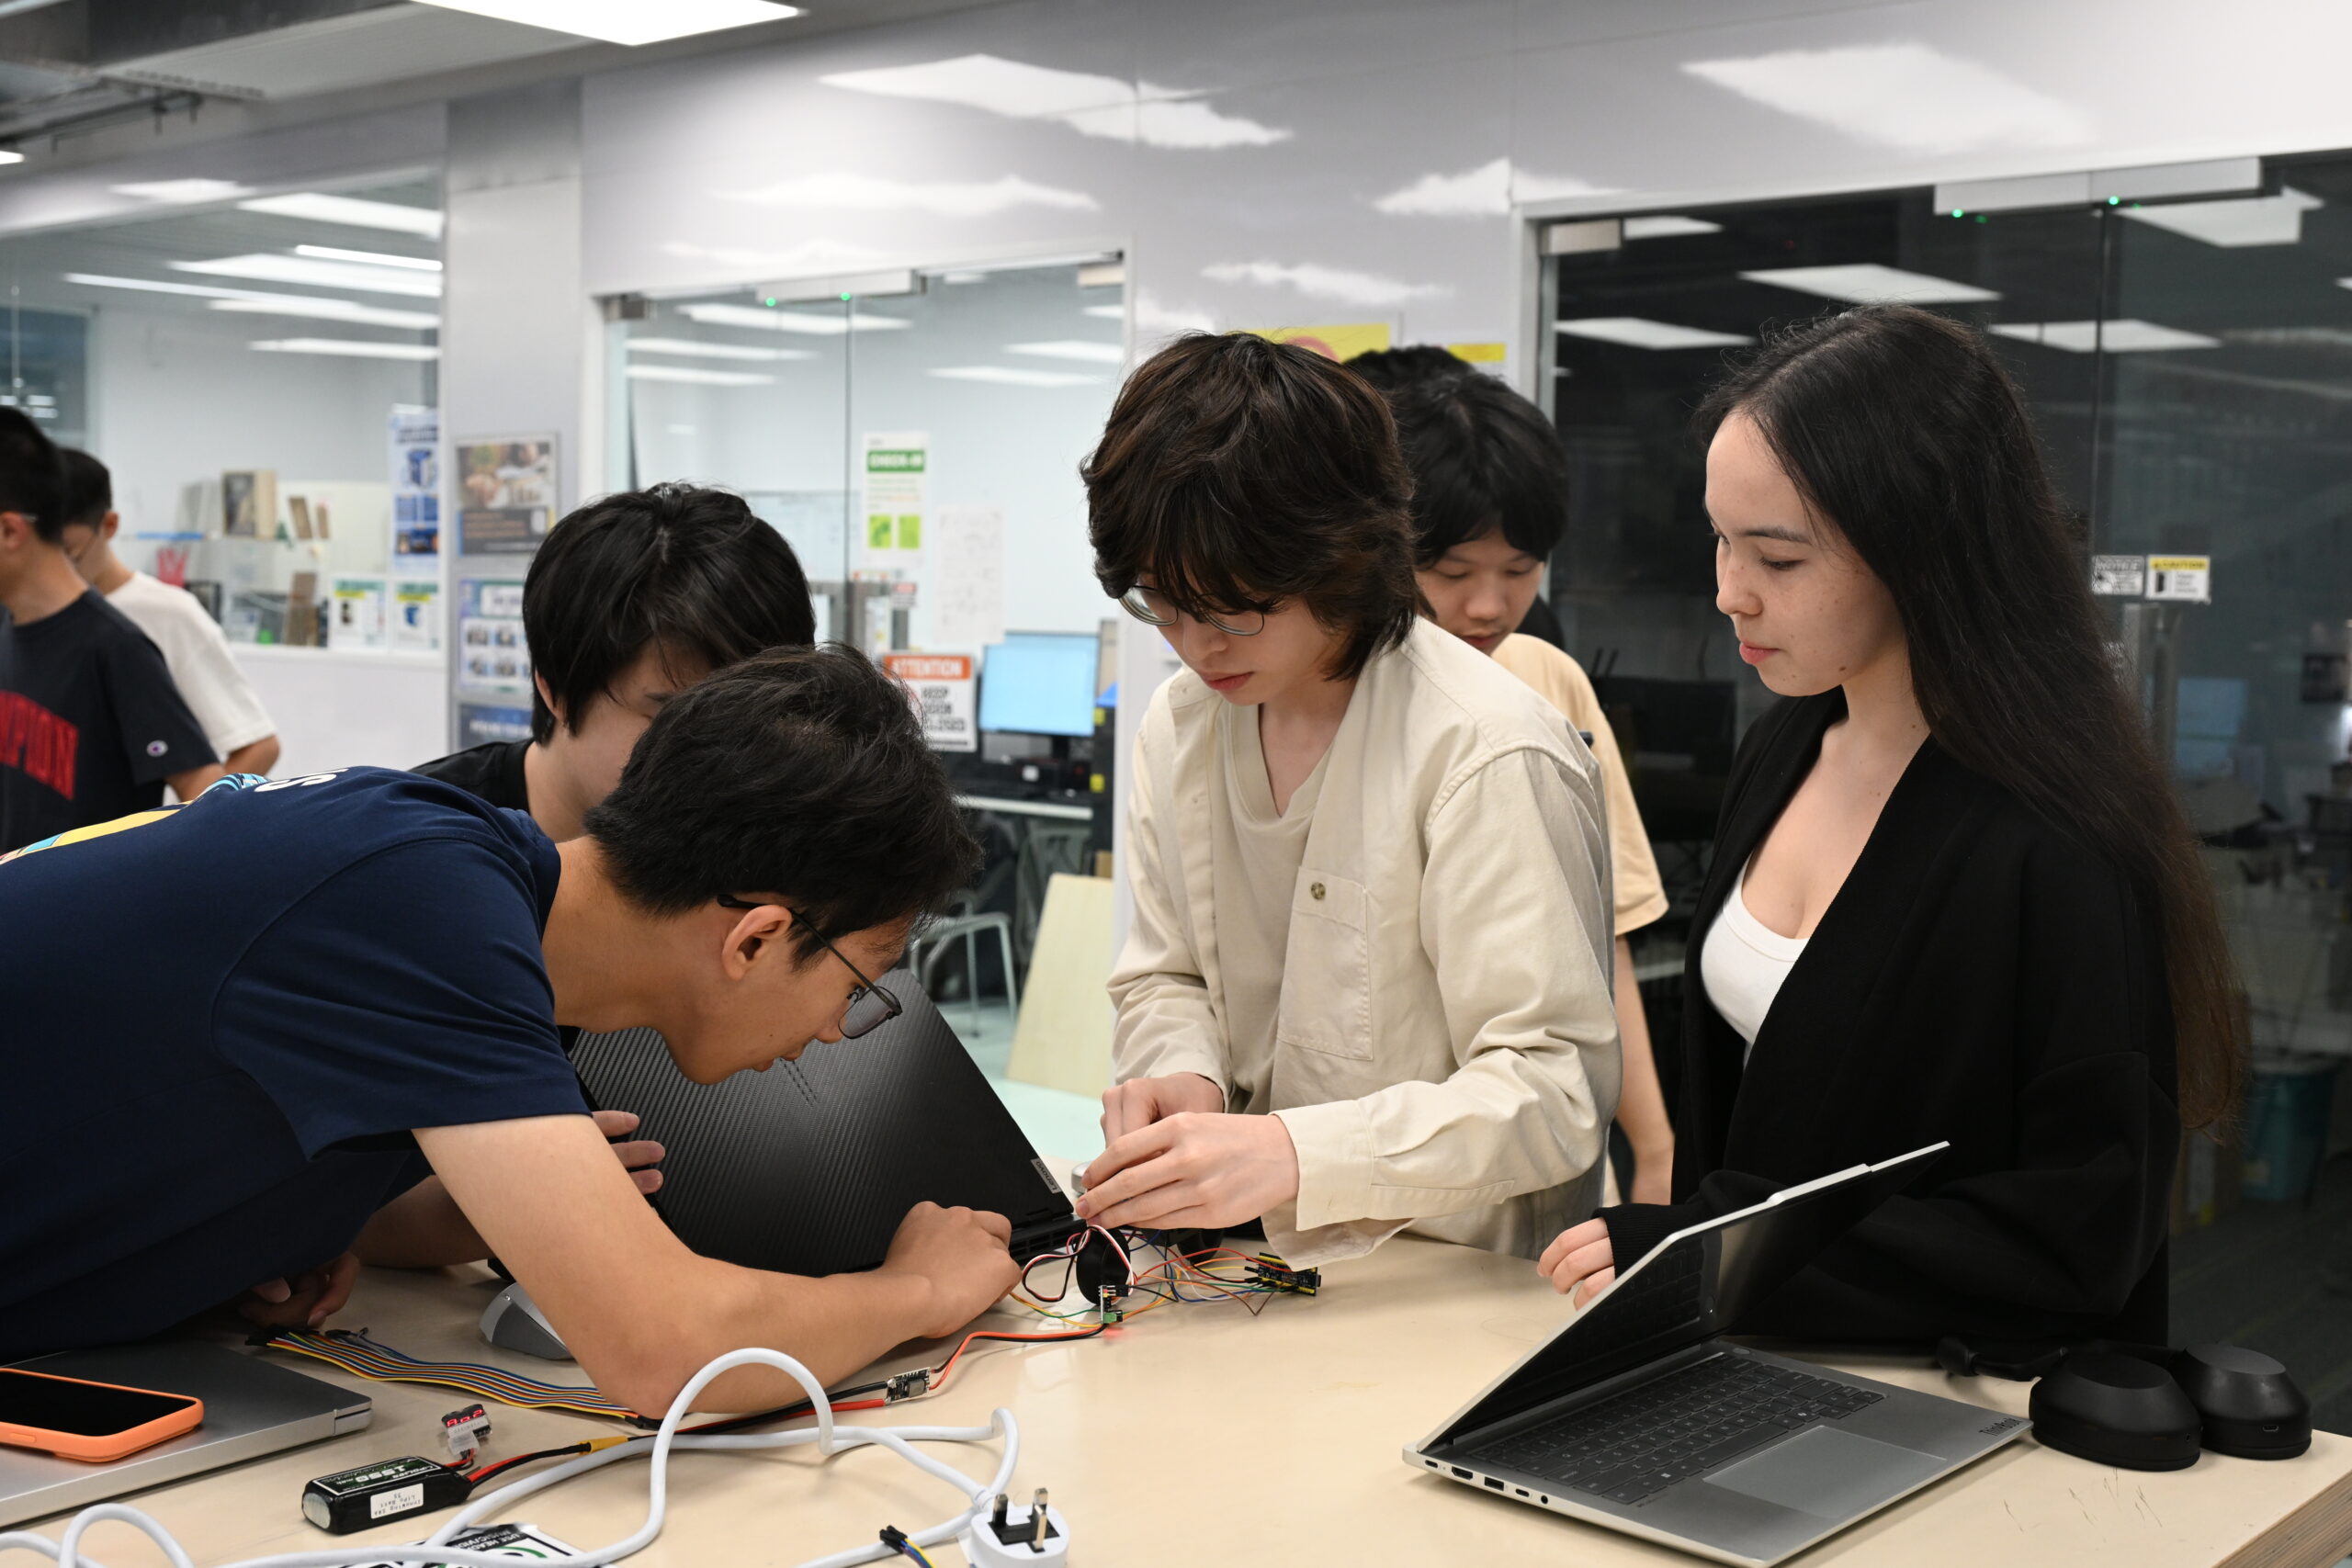
Apply the same balancing principles to physical hardware. By focusing on electronics and programming, you will use an IMU, STM32, motors, and foundational circuitry to build and test a system that detects tilt and automatically corrects itself to stay upright.

  • You will make: A working prototype bike that demonstrates the core principle of balancing.

What You Will Learn:

  • Turn sensor readings into useful angle data.
  • Design and tune a PID controller.
  • Connect an IMU, microcontroller, and motor using foundational electronics.
  • Apply basic CAD for structural components.
  • Test a controller and physics theories in simulation before using real hardware.
  • Apply this exact workflow to future robotics projects.

Continue with the Real Bike

This workshop is only the beginning. Selected participants will be invited to join the ongoing development of the real self-balancing bicycle. Once you have successfully simulated the physics and built a working controller, you will have the opportunity to apply those skills to advanced system integration and help bring the real bike to life.

Event Logistics

  • ๐Ÿ“ Location: InnoWing 1, Makerspace A
  • ๐Ÿ”ง Prerequisites: No prior knowledge or experience is required.Simulation files, starter code, and all hardware will be provided.

We look forward to building with you!

About the speaker

Professor Terence Leung , University College London (UCL)

Professor Terence Leung is Professor of Digital Health in the Department of Medical Physics and Biomedical Engineering at University College London (UCL) in the UK. Funded by the NIHR, USAID, EPSRC, BHF and industrial partners, his research activities encompass diffuse optics, acousto-optics, cerebral/muscle oxygenation monitoring, medical imaging, motion capture, healthcare app development and AI during his 25 years at UCL. He works closely with clinicians from UCLโ€™s 8 affiliated hospitals in the areas of neonatology, neurology, rhinology and ophthalmology.

Event photos